Detect Obstacles
Function:
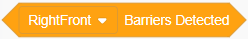
Description: This block is used to detect whether there are obstacles in a certain position of the car. Please start the ultrasonic sensor in the corresponding position before calling this module
Parameter: direction of obstacles
- Right Front
- Front
- Left Front
- Return:
- true: The obstacle has been detected
- false: No obstacle has been detected